Hiroyasu Tsukamoto
@Hiro_Tsukamoto · X
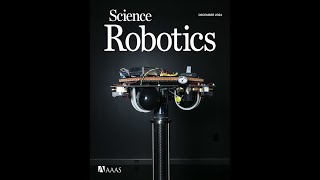
Caltechの同期&後輩の論文がまた表紙を飾ってる!負けてられないぜっ!! https://t.co/oE3HdCDKlq https://t.co/fNhrxRYBXo
Dec 9, 2024 · 26 likes · 1 share · 4,940 followers
View post →
Mentions
Extended reach
Total likes
Video views
AI synopsis
Participants express high interest and support for the algorithm's capabilities, illustrating this with statements about how SETS allows robots to simulate thousands of trajectories for optimal behavior, and emphasizing its potential to revolutionize autonomous navigation. The tone is positive and focused on technological innovation, reflecting the perceived importance and broad impact of the research.
Most discussions support the effectiveness and innovation of SETS, highlighting its success in enabling optimal decision-making in autonomous systems.
The technical nature and real-world applications of the algorithm generate high curiosity and enthusiasm among the participants.
Posts include references to specific methods, experimental validation, and potential applications, indicating a meaningful level of engagement.
The discussions suggest the algorithm has significant implications for robotics, AI, and autonomous decision-making, potentially transforming related fields.
Caltechの同期&後輩の論文がまた表紙を飾ってる!負けてられないぜっ!! https://t.co/oE3HdCDKlq https://t.co/fNhrxRYBXo
#Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optimal #Real-time decisions across various platforms by simulating thousands of trajectories. @Caltech @SciRobotics https://t.co/HWhJolUvJs https://t.co/M9ACJppmJg
Scientists have developed a real-time planning framework that enables optimal decision-making in autonomous robots in diverse and harsh environments. @CaltechEAS @SoonJoChung Read more in Science #Robotics: https://t.co/jEuzdLWuod https://t.co/d1PwpHIrM3
A new Science #Robotics study describes SETS—a real-time, tree-based algorithm that constructs a representation of the real world to aid robots make autonomous decisions on how to navigate complex spaces safely or assist humans with tasks. https://t.co/jEuzdLWuod https://t.co/Rd1ZseHwlY
Monte Carlo tree search with spectral expansion for planning with dynamical systems https://t.co/mUDrxm9jR3
@Caltech 【単一アルゴリズム自律航法】 カリフォルニア工科大学(@Caltech)の研究者らはロボットが非構造的かつ動的環境でリアルタイムに適切な意思決定を行う「Spectral Expansion Tree Search」(SETS)を開発。#ドローン #AI 《Monte Carlo tree search with spectral expansion for planning with https://t.co/Xyi5FcC1sN
SETS (Spectral Expansion Tree Search) is a new planning algorithm enabling real-time complex behavior planning. It simplifies continuous dynamics for robots, demonstrated on drones, spacecraft, and ground vehicles to…

In this video we explore Spectral Expansion Tree Search SETS, a novel planning algorithm that enables robots to make complex decisions in real time. SETS uses the spectrum of linearized systems to create a…
Monte Carlo Tree Search with Spectral Expansion for Planning with Dynamical Systems. https://t.co/GRDjEIwIMW
Benjamin Riviere, John Lathrop, Soon-Jo Chung Monte Carlo Tree Search with Spectral Expansion for Planning with Dynamical Systems https://arxiv.org/abs/2412.11270
Monte Carlo tree search with spectral expansion for planning with dynamical systems https://t.co/glCbY0qHjf #digitalmarketing #marketing #adtech #advertisement https://t.co/HfXumZxyG3
A new Science #Robotics study describes SETS—a real-time, tree-based algorithm that constructs a representation of the real world to aid robots make autonomous decisions on how to navigate complex spaces safely or assist humans with tasks. https://t.co/jEuzdLWuod https://t.co/Rd1ZseHwlY
Caltechの同期&後輩の論文がまた表紙を飾ってる!負けてられないぜっ!! https://t.co/oE3HdCDKlq https://t.co/fNhrxRYBXo
RT @SciRobotics: Scientists have developed a real-time planning framework that enables optimal decision-making in autonomous robots in dive…
RT @SciRobotics: Scientists have developed a real-time planning framework that enables optimal decision-making in autonomous robots in dive…
Scientists have developed a real-time planning framework that enables optimal decision-making in autonomous robots in diverse and harsh environments. @CaltechEAS @SoonJoChung Read more in Science #Robotics: https://t.co/jEuzdLWuod https://t.co/d1PwpHIrM3
MCTS with spectral expansion for planning with dynamical systems https://t.co/yuJwldxPCQ Spectral Expansion Tree Search (SETS) converges to a bound of the globally optimal solution for continuous, deterministic, and differentiable MDPs
RT @TechXplore_com: #Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optima…
SETS is a real-time planner that uses spectrum-based discrete representations to tackle complex, continuous problems. It enables robots to discover optimal behaviors and trajectories in diverse environments. https://t.co/t7RqPKPI0m
RT @ScottSAmyx: Monte Carlo tree search with spectral expansion for planning with dynamical systems https://t.co/mUDrxm9jR3
RT @TechXplore_com: #Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optima…
Monte Carlo tree search with spectral expansion for planning with dynamical systems https://t.co/mUDrxm9jR3
Monte Carlo tree search with spectral expansion for planning with dynamical systems www.science.org/doi/10.1126/...
RT @iw_toshiki: @Caltech 【単一アルゴリズム自律航法】 カリフォルニア工科大学(@Caltech)の研究者らはロボットが非構造的かつ動的環境でリアルタイムに適切な意思決定を行う「Spectral Expansion Tree Search」(SETS)を…
RT @TechXplore_com: #Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optima…
Monte Carlo tree search with spectral expansion for planning with dynamical systems. #science #publication #research #publications https://t.co/Hv121FEF89
RT @TechXplore_com: #Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optima…
RT @TechXplore_com: #Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optima…
#Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optimal #Real-time decisions across various platforms by simulating thousands of trajectories. @Caltech @SciRobotics https://t.co/HWhJolUvJs https://t.co/M9ACJppmJg
RT @TechXplore_com: #Caltech researchers have developed the Spectral Expansion Tree Search (SETS) algorithm, enabling robots to make optima…
@Caltech 【単一アルゴリズム自律航法】 カリフォルニア工科大学(@Caltech)の研究者らはロボットが非構造的かつ動的環境でリアルタイムに適切な意思決定を行う「Spectral Expansion Tree Search」(SETS)を開発。#ドローン #AI 《Monte Carlo tree search with spectral expansion for planning with https://t.co/Xyi5FcC1sN