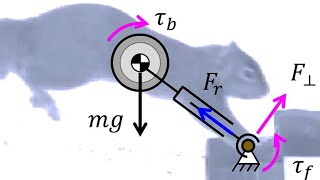
Discussions highlight the innovative nature of the study, with words like 'breakthrough,' 'advancement,' and references to applying squirrel balance strategies. Many posts emphasize the potential for improved robotic agility in environments like forests, reflecting a positive outlook on the research's impact.
AgreementModerate agreement
Most discussions express support or admiration for the scientific advances, with some highlighting how the study offers promising real-world applications.
InterestHigh interest
The topic sparks significant interest, evident from enthusiasm for squirrel-inspired robotics and breakthroughs in agility and balance.
EngagementModerate engagement
Participants engage thoughtfully, mentioning specific techniques such as 'radial force control' and comparing robot performance to squirrels, indicating moderate depth.
ImpactModerate impact
Posts suggest that the research could have meaningful impacts on robotics and practical applications in complex environments, though some see it as a step rather than a breakthrough.
Abstract in brief
This study explores how a monopedal robot called Salto1P can perform branch-to-branch leaps and landings, similar to squirrels, by using leg length control to improve balance on narrow supports with limited grip, even without strong grasping torque.
The research compares the robot's balance strategy with that of real squirrels and finds that controlling radial force helps reduce the torques needed to maintain balance during landings, significantly expanding the robot's and squirrels' ability to land successfully from various initial conditions.
Implementing simple radial force control techniques alongside traditional balance methods increases the robot's and squirrels' range of successful landings by 230% and 470%, respectively, allowing better stability across different angles and momentum during arboreal jumps.]
Scientists have developed a strategy that enables a one-legged robot named #Salto to land and balance upright after jumping from branch to branch, like a squirrel. @illinoismechse @MITMechE @UCBerkeley
Learn more in Science #Robotics: https://t.co/8XX3p91mgB https://t.co/XYfEP1dVUh
Mar 21, 2025 · 38 likes · 8 shares · 27,673 followersView post →
V
Vsauce2
@VsauceTwo · X
Herpes Gum?
[new mind blow] --> https://t.co/cSJJQYaPzk https://t.co/qmcg735oKq
#Engineers have developed a #Robot inspired by squirrels that can leap and land on narrow perches. This advancement could enhance robotic agility in complex environments like forests and construction sites. @SciRobotics https://t.co/QLLOV2ipUV https://t.co/Z5YS762Kd3
Mar 19, 2025 · 18 likes · 10 shares · 21,295 followersView post →
SR
Science Robotics
@SciRobotics · X
A new Science #Robotics study describes a #squirrel-inspired #balance strategy that improves a one-legged robot’s chances of landing upright after jumping from branch to branch. https://t.co/8XX3p90Or3 https://t.co/pb6ioD9Hm0
Mar 25, 2025 · 10 likes · 1 share · 27,673 followersView post →
UB
UNO Biomechanics
@UNOBiomechanics · X
Congratulations to Associate Professor Nate Hunt on his recent publication in the journal Science Robotics "Monopedal robot branch-to-branch leaping and landing inspired by squirrel balance control"
It even captured the attention of late-night talk show host Stephen Colbert! https://t.co/UTj2uRBoe0
High-capacity stretchable batteries are essential for advanced wearables. This video explores how new fluid electrode designs allow for increased capacity without compromising flexibility, demonstrating excellent…
This study explores how a monopedal robot called Salto1P performs branch-to-branch leaps and landings, similar to squirrels, by using leg length control to improve balance on narrow supports with limited grip, even…
Congratulations to Associate Professor Nate Hunt on his recent publication in the journal Science Robotics "Monopedal robot branch-to-branch leaping and landing inspired by squirrel balance control"
It even captured the attention of late-night talk show host Stephen Colbert! https://t.co/UTj2uRBoe0
A new Science #Robotics study describes a #squirrel-inspired #balance strategy that improves a one-legged robot’s chances of landing upright after jumping from branch to branch. https://t.co/8XX3p90Or3 https://t.co/pb6ioD9Hm0
Mar 25, 2025 · 10 likes · 1 share · 27,673 followersView post →
RT @SciRobotics: Scientists have developed a strategy that enables a one-legged robot named #Salto to land and balance upright after jumpin…
Mar 21, 2025 · 8 shares · 6,392 followersView post →
SU
Some UK Tesla Guy (UnSupervised...)
@SomeUKTeslaGuy · X
RT @SciRobotics: Scientists have developed a strategy that enables a one-legged robot named #Salto to land and balance upright after jumpin…
Mar 21, 2025 · 8 shares · 733 followersView post →
RS
Robert Scoble
@Scobleizer · X
RT @SciRobotics: Scientists have developed a strategy that enables a one-legged robot named #Salto to land and balance upright after jumpin…
Mar 21, 2025 · 8 shares · 543,036 followersView post →
SR
Science Robotics
@SciRobotics · X
Scientists have developed a strategy that enables a one-legged robot named #Salto to land and balance upright after jumping from branch to branch, like a squirrel. @illinoismechse @MITMechE @UCBerkeley
Learn more in Science #Robotics: https://t.co/8XX3p91mgB https://t.co/XYfEP1dVUh
Mar 21, 2025 · 38 likes · 8 shares · 27,673 followersView post →
ST
Steve Trutane
@trutane.bsky.social · Bluesky
Parkour breakthrough in robotics by studying squirrels:
Study: Monopedal robot branch-to-branch leaping and landing inspired by squirrel balance control www.science.org/doi/10.1126/... ($)
It’s all about “radial force balance control”
RT @TechXplore_com: #Engineers have developed a #Robot inspired by squirrels that can leap and land on narrow perches. This advancement cou…
Mar 19, 2025 · 10 shares · 1,231 followersView post →
PO
Phys.org
@physorg_com · X
RT @TechXplore_com: #Engineers have developed a #Robot inspired by squirrels that can leap and land on narrow perches. This advancement cou…
Mar 19, 2025 · 10 shares · 1,023,955 followersView post →
T
TechXplore
@TechXplore_com · X
#Engineers have developed a #Robot inspired by squirrels that can leap and land on narrow perches. This advancement could enhance robotic agility in complex environments like forests and construction sites. @SciRobotics https://t.co/QLLOV2ipUV https://t.co/Z5YS762Kd3
Mar 19, 2025 · 18 likes · 10 shares · 21,295 followersView post →