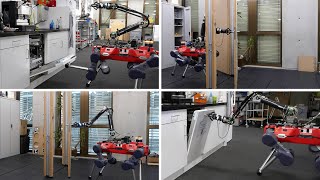
Several discussions highlight specific aspects of the article, such as the ability of robots to open dishwashers and traverse complex environments, using phrases like 'this is amazing!' and 'new program takes us one step closer to autonomous robots' to indicate excitement and significance. The positive tone and choice of engaging language in these discussions reflect a strong collective belief in the transformative potential of the research.
AgreementStrong agreement
The majority of discussions express strong support and enthusiasm for the research findings.
InterestHigh interest
Contributors display high curiosity about the concepts and applications presented in the publication.
EngagementHigh engagement
Many participants engaged deeply, discussing methodologies and potential real-world implications.
ImpactHigh impact
Most users perceive the research as having a profound influence on the future of robotics.
Abstract in brief
Loco-manipulation planning skills are crucial for robots to function effectively in everyday settings and involve coordinating complex movements and contact interactions.
Existing methods typically rely on rigid structures like state machines or expert demonstrations, limiting adaptability.
The proposed framework uses a minimally guided approach that leverages integrated task and motion planning to autonomously discover movements and contact schedules for robots, leading to the successful execution of real-world tasks such as operating dishwashers and opening doors.
Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or closing heavy dishwashers, is challenging. Check out our proposed solution for our legged mobile manipulator:
https://t.co/JEUC8G9kAf
@SciRobotics @ETH_en https://t.co/F78WgkyJYw
Aug 16, 2023 · 182 likes · 28 shares · 15,954 followersView post →
Aug 17, 2023 · 127 likes · 37 shares · 21,747 followersView post →
SR
Science Robotics
@SciRobotics · X
A planning and control approach from @ETH_en for robots generates versatile whole-body, multi-contact solutions in loco-manipulation tasks. https://t.co/Aab9nqBEOC https://t.co/qyVVz7HCRY
Aug 16, 2023 · 58 likes · 6 shares · 27,680 followersView post →
SR
Science Robotics
@SciRobotics · X
In Science #Robotics, see how #Robots can traverse through doors and open dishwashers using a versatile multi-contact planning and control approach. @leggedrobotics https://t.co/8Sj8qfqTLH https://t.co/4aF7jcpJkY
Oct 17, 2023 · 53 likes · 6 shares · 27,680 followersView post →
SM
Science Magazine
@ScienceMagazine · X
New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher doors, new work could enable the one-day creation of autonomous robots that can move through environments deftly while completing tasks. https://t.co/D01ivM8lJ9 https://t.co/p0hBbEVRli
Aug 21, 2023 · 41 likes · 12 shares · 4,515,908 followersView post →
SM
Science Magazine
@ScienceMagazine · X
New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher doors, new work could enable the one-day creation of autonomous robots that can move through environments deftly while completing tasks. https://t.co/ENqo5Y80Uh https://t.co/8mN1sC3vny
Aug 16, 2023 · 36 likes · 7 shares · 4,515,908 followersView post →
Loco-manipulation planning skills are crucial for robots' effectiveness in daily environments. This video presents a minimally guided framework for autonomous planning of movements and contact schedules, enabling robots…
Researchers at ETH Zurich present a novel control framework for robots that enables them to perform complex tasks like operating dishwashers and opening doors. This minimally guided approach allows robots to…
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Dec 12, 2023 · 28 shares · 515 followersView post →
RL
Robotic Systems Lab
@leggedrobotics · X
RT @SciRobotics: In Science #Robotics, see how #Robots can traverse through doors and open dishwashers using a versatile multi-contact plan…
Oct 17, 2023 · 6 shares · 16,143 followersView post →
GŻ
Grażyna Żebrowska
@gra_ze · X
RT @SciRobotics: In Science #Robotics, see how #Robots can traverse through doors and open dishwashers using a versatile multi-contact plan…
Oct 17, 2023 · 6 shares · 462 followersView post →
SR
Science Robotics
@SciRobotics · X
In Science #Robotics, see how #Robots can traverse through doors and open dishwashers using a versatile multi-contact planning and control approach. @leggedrobotics https://t.co/8Sj8qfqTLH https://t.co/4aF7jcpJkY
Oct 17, 2023 · 53 likes · 6 shares · 27,680 followersView post →
JN
Jaroslav Novotný
@novotnyjarosl · X
RT @leggedrobotics: For those interested in diving deeper into our methodology and findings, here's the full paper:
https://t.co/lK6CmnAfC…
Interview with Jean Pierre Sleiman, author of the paper “Versatile multicontact planning and control for legged loco-manipulation” https://t.co/yXCWVbXL0F https://t.co/09niih3lWQ
Interview with Jean Pierre Sleiman, author of the paper “Versatile multicontact planning and control for legged loco-manipulation” https://t.co/Cw2ITmuW9e
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 21, 2023 · 12 shares · 61 followersView post →
E
Eliyahu
@RosenthalEllery · X
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 21, 2023 · 12 shares · 6,981 followersView post →
SM
Science Magazine
@ScienceMagazine · X
New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher doors, new work could enable the one-day creation of autonomous robots that can move through environments deftly while completing tasks. https://t.co/D01ivM8lJ9 https://t.co/p0hBbEVRli
Aug 21, 2023 · 41 likes · 12 shares · 4,515,908 followersView post →
AM
Automatically Made
@AMautomatics · X
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Aug 21, 2023 · 28 shares · 112 followersView post →
Aug 18, 2023 · 37 shares · 205 followersView post →
SR
Science Robotics
@SciRobotics · X
By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher doors, new work could enable the one-day creation of autonomous robots that can move through environments deftly while completing tasks. @ETH_en https://t.co/LQP8e5P01C https://t.co/Ose153tykP
Aug 18, 2023 · 35 likes · 5 shares · 27,680 followersView post →
SI
Solar Governance Institute
@GovernanceSolar · X
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Aug 18, 2023 · 28 shares · 146 followersView post →
Aug 18, 2023 · 37 shares · 16,301 followersView post →
D
Discoveryflow
@discoveryflow · X
LEGGED ROBOTICS at ETH Zürich
ROBOTS are now able to open doors and dishwasher doors. BOT looks like spot from boston dyanamics have head like arm
[source-t.yamazaki https://t.co/EyMcCrwJQz]
#quadruped #robot #loco_manipulation #motion_planning #ANYmal #ANYbotics #ETH_Zurich https://t.co/wUqx6XpKtF
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 16, 2023 · 7 shares · 2,447 followersView post →
GW
Greg Warzecha
@greg_warzecha · X
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Aug 16, 2023 · 28 shares · 288 followersView post →
SM
Souradip M
@Souradip_mkd · X
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Aug 16, 2023 · 28 shares · 74 followersView post →
JM
Jaime Aguilar M
@Jaguilam2003 · X
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Aug 16, 2023 · 28 shares · 2,219 followersView post →
S
sciencenews
@Scieducation1 · X
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 16, 2023 · 7 shares · 5,125 followersView post →
HX
Haoyu Xiong
@Haoyu_Xiong_ · X
RT @leggedrobotics: Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or c…
Aug 16, 2023 · 28 shares · 3,198 followersView post →
A
AnDy
@GODPorSiempre · X
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 16, 2023 · 7 shares · 8,825 followersView post →
B
BrooklynMOMNYC
@BrooklynMOMNYC · X
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 16, 2023 · 7 shares · 437 followersView post →
JL
Jorge Lucares
@Charlygatooo · X
RT @ScienceMagazine: New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher…
Aug 16, 2023 · 7 shares · 2,555 followersView post →
SM
Science Magazine
@ScienceMagazine · X
New in @SciRobotics: By tackling the nuanced facets of self-movement required during tasks such as closing dishwasher doors, new work could enable the one-day creation of autonomous robots that can move through environments deftly while completing tasks. https://t.co/ENqo5Y80Uh https://t.co/8mN1sC3vny
Aug 16, 2023 · 36 likes · 7 shares · 4,515,908 followersView post →
RL
Robotic Systems Lab
@leggedrobotics · X
For those interested in diving deeper into our methodology and findings, here's the full paper:
https://t.co/lK6CmnAfCB
#LeggedRobots #MobileManipulation
Aug 16, 2023 · 8 likes · 1 share · 16,143 followersView post →
RL
Robotic Systems Lab
@leggedrobotics · X
Crafting multi-contact loco-manipulation behaviors for sparsely-defined tasks, like traversing spring-loaded doors or closing heavy dishwashers, is challenging. Check out our proposed solution for our legged mobile manipulator:
https://t.co/JEUC8G9kAf
@SciRobotics @ETH_en https://t.co/F78WgkyJYw
Aug 16, 2023 · 182 likes · 28 shares · 15,954 followersView post →
HC
Haoyu Xiong @CoRL
@Haoyu_Xiong_ · X
RT @SciRobotics: A planning and control approach from @ETH_en for robots generates versatile whole-body, multi-contact solutions in loco-ma…
Aug 16, 2023 · 6 shares · 3,338 followersView post →
XZ
Xie Zhaoming
@zhaomingxie · X
RT @SciRobotics: A planning and control approach from @ETH_en for robots generates versatile whole-body, multi-contact solutions in loco-ma…
Aug 16, 2023 · 6 shares · 404 followersView post →
SR
Science Robotics
@SciRobotics · X
A planning and control approach from @ETH_en for robots generates versatile whole-body, multi-contact solutions in loco-manipulation tasks. https://t.co/Aab9nqBEOC https://t.co/qyVVz7HCRY
Aug 16, 2023 · 58 likes · 6 shares · 27,680 followersView post →