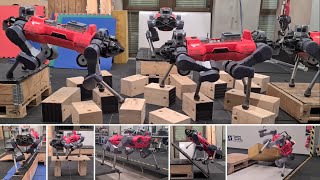
Discussions prominently highlight the hybrid control framework's ability to enhance robotic performance in difficult terrains, as seen in phrases like 'an impressive demonstration' and 'game changer' when referencing the ANYmal robot. The choice of such enthusiastic language, along with specific references to the techniques used, adds to the overall positive sentiment, showcasing both excitement and validation of the publication's contributions to robotics.
AgreementStrong agreement
The majority of discussions reflect strong support for the ideas presented in the publication, with many users agreeing on the significance of the advancements in legged locomotion control.
InterestHigh interest
There is a notable curiosity surrounding the hybrid control architecture, as many contributors express excitement about its applications in robotics.
EngagementModerate engagement
While some posts demonstrate deep technical insights, others tend to summarize findings rather than delve into specifics.
ImpactHigh impact
Several contributors believe this research will significantly influence the future of robotic navigation and applications in challenging environments.
Abstract in brief
The study focuses on enhancing legged locomotion control by integrating model-based planning with deep reinforcement learning techniques.
This hybrid approach aims to improve foot placement accuracy, robustness, and the ability to navigate various terrains efficiently.
Results indicate that the proposed method outperforms traditional techniques, especially in challenging environments, while also demonstrating generalization across different optimization methods.
Exactly 2 years ago during #Arche, my thesis supervisor @FJenelten51897 and I deployed this mpc+rl hybrid controller on very complicated collapsed buildings. Two years later its performance is still at the top tier!
DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboticsolutions #leggedrobot #robot #robotdog #ai #reinforcementlearning #armasuisse #ScienceRoboticsResearch #anymal #searchandrescue #ARCHE2023 https://t.co/QkM3PBwNzG
Jan 25, 2024 · 77 likes · 12 shares · 16,161 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improve foot placement and agility on unstructured terrain—and recover from slipping.
Read more in @SciRobotics: https://t.co/AKNziAHKu3 https://t.co/u7Lgd2OX1I
Feb 5, 2024 · 60 likes · 8 shares · 4,517,554 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/fkWAr8WDNC https://t.co/WgQ7Pc4SUX
Jan 22, 2024 · 47 likes · 11 shares · 4,517,554 followersView post →
RL
Robotic Systems Lab
@leggedrobotics · X
3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accurate and robust locomotion (#ScienceRoboticsResearch, @ETH_en, @ScienceMagazine).
Full video: https://t.co/RI0MtxMANr
Paper: https://t.co/KOGFn0hepg https://t.co/0GklUKjuG8
Jan 17, 2024 · 47 likes · 8 shares · 15,953 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/vTrQqXgiB1 https://t.co/ZuyEwhZkFe
Jan 18, 2024 · 43 likes · 12 shares · 4,517,554 followersView post →
We have combined trajectory optimization and reinforcement learning to enhance legged locomotion control. This hybrid approach improves foot placement accuracy and robustness while navigating diverse terrains…
Explore the frontier of search-and-rescue capabilities of legged robots as ANYmal adapts to challenging terrains. This video highlights the innovative Deep Tracking Control method that enhances locomotion, foot…
Exactly 2 years ago during #Arche, my thesis supervisor @FJenelten51897 and I deployed this mpc+rl hybrid controller on very complicated collapsed buildings. Two years later its performance is still at the top tier!
So they have the best motion planning.
And perception part is low hanging (https://t.co/890VgJaVDq)
And motion tracking is also low hanging (https://t.co/9yP19UeF3W)(don't think BD needs to all-in RL here, so https://t.co/jLJv0G7ggZ)
Apr 17, 2024 · 1 like · 5,535 followersView post →
SC
Slanderman, Corrupting-the-Constructive
@DeskDuncan · X
Replicating this, or something similar, in 18 months. How exactly do questions you ask get “better” as you know more about the subject?
https://t.co/ssDXEqGf6D
DTC: Deep Tracking Control: Trajectory optimization and reinforcement learning are combined for versatile and robust perceptive legged locomotion. https://t.co/tjWFEZk0mX
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Feb 5, 2024 · 8 shares · 1,637 followersView post →
Pψ
Psicólogo Celestino González-Fernández ψ
@Tecnoestres · X
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Feb 5, 2024 · 8 shares · 2,909 followersView post →
RN
Ricardo B�nffy -
@0xDEADBEEFCAFE · X
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Feb 5, 2024 · 8 shares · 1,474 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improve foot placement and agility on unstructured terrain—and recover from slipping.
Read more in @SciRobotics: https://t.co/AKNziAHKu3 https://t.co/u7Lgd2OX1I
Feb 5, 2024 · 60 likes · 8 shares · 4,517,554 followersView post →
R
Renaissance
@alternative200 · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Feb 2, 2024 · 12 shares · 1,545 followersView post →
AD
Aaro Dust
@aaron_dustin · X
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Jan 31, 2024 · 9 shares · 220 followersView post →
NC
Nelson Maica C
@jupiterxc · X
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Jan 31, 2024 · 9 shares · 3,810 followersView post →
EA
Eng. Ayoub Ahmed
@eng_aaube29 · X
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Jan 31, 2024 · 9 shares · 566 followersView post →
EM
Elisabetta Massone
@EMassone2 · X
RT @ScienceMagazine: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improv…
Jan 31, 2024 · 9 shares · 200 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improve foot placement and agility on unstructured terrain—and recover from slipping.
Read more in @SciRobotics: https://t.co/m2tL2HKBhI https://t.co/Ikb4fvz8cB
Jan 31, 2024 · 36 likes · 9 shares · 4,517,554 followersView post →
R
RoboDepot
@RoboDepot · X
RT @RoboDepot: An impressive demonstration from ETH Zürich of how their quadruped robot uses deep tracking control to maintain stability ov…
Jan 29, 2024 · 4 shares · 1,167 followersView post →
S
ScottCardano
@ScottCardano · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in @SciRobotics: https://t.co/xsonBANyxl https://t.co/iCgQzdE95t
Jan 29, 2024 · 39 likes · 6 shares · 4,517,554 followersView post →
A
Adam
@orientalfun · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 27, 2024 · 12 shares · 30 followersView post →
SY
Sudhir Pratap Yadav
@sudhirPyadav · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 26, 2024 · 12 shares · 61 followersView post →
S
Shahudullah
@ShahudullahKhan · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 26, 2024 · 12 shares · 207 followersView post →
JN
Josh Njuki
@Josh_Njuki · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 26, 2024 · 12 shares · 41 followersView post →
BG
Blaze (Balázs Galambosi)
@gblazex · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 25, 2024 · 12 shares · 1,253 followersView post →
C
camron
@CamronBergh · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 25, 2024 · 12 shares · 197 followersView post →
R
Rakesh
@rozeappletree · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 25, 2024 · 12 shares · 217 followersView post →
SK
Sai Kishor Kothakota
@manforrobots · X
RT @leggedrobotics: DTC: Deep Tracking Control - Behind the Scenes
video: https://t.co/ZJjXVGd5OY
paper: https://t.co/KOGFn0hepg
#roboti…
Jan 25, 2024 · 12 shares · 210 followersView post →
TR
Terra Rara
@Terra_Rara · X
UMA ARQUITETURA DE CONTROLE HÍBRIDA QUE COMBINA VANTAGENS DOS ATUAIS CONTROLES DE ROBÔS QUADRÚPEDES
https://t.co/2wX3iZskup
Credibilidade: 999
#Robô
A arquitetura dá aos robôs de 4 patas melhores capacidades de locomoção em terrenos acidentados.
Veja em:
https://t.co/AlSuc4VLcn https://t.co/2i8SxCF6uc
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in @SciRobotics: https://t.co/cLbfqchYec https://t.co/CemRyPtmNy
Jan 24, 2024 · 31 likes · 4 shares · 4,517,554 followersView post →
NS
NFT Shiller (
@coltchromu38246 · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 23, 2024 · 11 shares · 18 followersView post →
GJ
GlobalBritainTech #WorldRobotDay 25 Jan
@WorldRobotDay · X
RT @SciRobotics: A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improve fo…
Jan 23, 2024 · 4 shares · 947 followersView post →
SR
Science Robotics
@SciRobotics · X
A hybrid control architecture combining reinforcement learning and trajectory optimization let the ANYmal robot improve foot placement and agility on unstructured terrain—and recover from slipping. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/BZ8r8tNr3y https://t.co/osTB6hwcxK
Jan 23, 2024 · 36 likes · 4 shares · 27,691 followersView post →
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/hcUqmGliyZ https://t.co/IXaBdlXgXy
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 23, 2024 · 11 shares · 382 followersView post →
W
wikii
@thejana_wikii · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 23, 2024 · 11 shares · 2,508 followersView post →
デイ
ディープ5インパクト
@ChI5lFUIHBtcTa1 · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 580 followersView post →
JC
JuanMatias-CreadorNarradorVisual
@JNarradorVisual · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 1,235 followersView post →
JN
Jaroslav Novotný
@novotnyjarosl · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 604 followersView post →
A
Abelus
@abelusmx · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 380 followersView post →
JF
jan gilley faiella
@jangillefaiella · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 94 followersView post →
乙
#乙ꫀʀoᴾᴿᴱˢˢᵁᴿᴱ
@ZeroPressure_ · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 9,690 followersView post →
HH
Hal Herzog
@herzoghal · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 4,763 followersView post →
XP
Xeno/Douglas/Pepe
@AllenPepe · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 22, 2024 · 11 shares · 1,151 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/fkWAr8WDNC https://t.co/WgQ7Pc4SUX
Jan 22, 2024 · 47 likes · 11 shares · 4,517,554 followersView post →
E
eastvillagetwt
@eastvillagetwt · X
RT @RoboDepot: An impressive demonstration from ETH Zürich of how their quadruped robot uses deep tracking control to maintain stability ov…
Jan 22, 2024 · 4 shares · 2,457 followersView post →
E
Expanse
@heft_ig · X
RT @RoboDepot: An impressive demonstration from ETH Zürich of how their quadruped robot uses deep tracking control to maintain stability ov…
Jan 21, 2024 · 4 shares · 279 followersView post →
S
ShiftingScenes
@ScenesShifting · X
RT @RoboDepot: An impressive demonstration from ETH Zürich of how their quadruped robot uses deep tracking control to maintain stability ov…
Jan 21, 2024 · 4 shares · 2,398 followersView post →
S佐
Sato Takaaki/佐藤隆明
@satotakaaki · X
RT @iw_toshiki: @leggedrobotics @eth_dmavt @ETH @ETH_en 【四足歩行のハイブリッド制御】
ETH(@ETH)Robotic Systems Lab(@leggedrobotics)の研究者は軌道最適化(TO)と強化学習(RL…
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 18, 2024 · 12 shares · 2,604 followersView post →
A
Abelus
@abelusmx · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 18, 2024 · 12 shares · 380 followersView post →
XZ
Xie Zhaoming
@zhaomingxie · X
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
Jan 18, 2024 · 8 shares · 398 followersView post →
BN
Brad Nelson
@hpdnelson · X
RT @SciRobotics: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfa…
Jan 18, 2024 · 2 shares · 170 followersView post →
IT
Iwahori Toshiki
@iw_toshiki · X
@leggedrobotics @eth_dmavt @ETH @ETH_en 【四足歩行のハイブリッド制御】
ETH(@ETH)Robotic Systems Lab(@leggedrobotics)の研究者は軌道最適化(TO)と強化学習(RL)との組み合わせにより、脚式ロボットの正確でロバストな歩行を実現するハイブリッド制御アーキテクチャを開発。
《DTC: Deep Tracking Control》https://t.co/GyPHpAwILx https://t.co/d3NQQuNdTx https://t.co/dkJekhMUY9
Jan 18, 2024 · 2 likes · 2 shares · 9,998 followersView post →
R
RoboDepot
@RoboDepot · X
An impressive demonstration from ETH Zürich of how their quadruped robot uses deep tracking control to maintain stability over complex terrain.
https://t.co/kgXxFNzrLj #robot #robotics #ai #artificialintelligence #openai #tesla Like, share, and follow for more! https://t.co/7ZE8XKevlx
Jan 18, 2024 · 21 likes · 4 shares · 1,167 followersView post →
F
FrostyDesign
@FrostyDesign_JP · X
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
Jan 18, 2024 · 8 shares · 2,629 followersView post →
JC
JuanMatias-CreadorNarradorVisual
@JNarradorVisual · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 18, 2024 · 12 shares · 1,235 followersView post →
ลง
ลัคกี้ โหมดฤดูงาน
@sr_wiz · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 18, 2024 · 12 shares · 1,612 followersView post →
GŻ
Grażyna Żebrowska
@gra_ze · X
RT @SciRobotics: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfa…
Jan 18, 2024 · 2 shares · 462 followersView post →
AG
Astro Gio
@Astro_Gio · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 18, 2024 · 12 shares · 15 followersView post →
NC
Nelson Maica C
@jupiterxc · X
RT @ScienceMagazine: A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier s…
Jan 18, 2024 · 12 shares · 3,810 followersView post →
SR
Science Robotics
@SciRobotics · X
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/zImvzAdkwB https://t.co/7yj4E6fKu6
Jan 18, 2024 · 17 likes · 2 shares · 27,691 followersView post →
SM
Science Magazine
@ScienceMagazine · X
A new hybrid control framework helped a four-legged, dog-sized, autonomous #robot called ANYmal move across trickier surfaces. @ETH_en @leggedrobotics
Read more in Science #Robotics: https://t.co/vTrQqXgiB1 https://t.co/ZuyEwhZkFe
Jan 18, 2024 · 43 likes · 12 shares · 4,517,554 followersView post →
AS
Akoko Mbero Mr Stockmann
@akoko_mbero · X
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
Jan 18, 2024 · 8 shares · 350 followersView post →
FD
Frank Dellaert
@fdellaert · X
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
Jan 17, 2024 · 8 shares · 14,238 followersView post →
AS
Aziz Shamsah
@AziizSH · X
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
Jan 17, 2024 · 8 shares · 614 followersView post →
MF
Mitchell Fogelson
@fogmb · X
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
RT @leggedrobotics: 3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accur…
Jan 17, 2024 · 8 shares · 117 followersView post →
RL
Robotic Systems Lab
@leggedrobotics · X
3. In our most recent work, we have combined TO and RL to synthesize a unifying control policy that leads to both accurate and robust locomotion (#ScienceRoboticsResearch, @ETH_en, @ScienceMagazine).
Full video: https://t.co/RI0MtxMANr
Paper: https://t.co/KOGFn0hepg https://t.co/0GklUKjuG8
Jan 17, 2024 · 47 likes · 8 shares · 15,953 followersView post →